


Scan Computers Partners With OLO Robotics To Simplify Robot Deployment


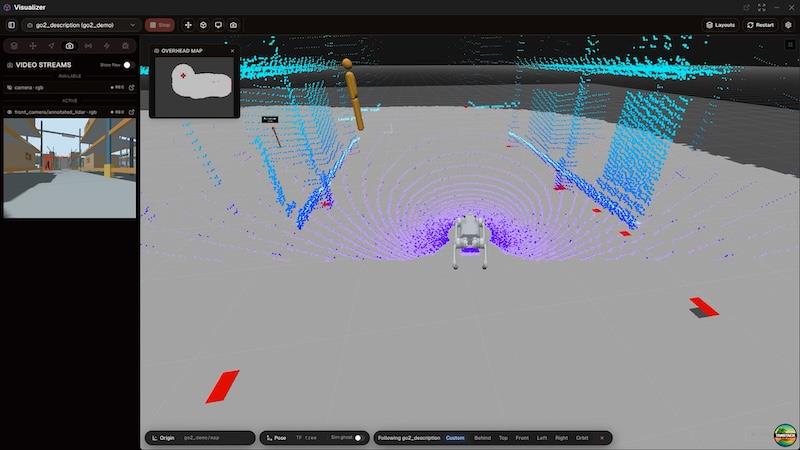
OLO's platform brings teleoperation, simulation and autonomous navigation together in the browser. With it, you can quickly and easily test robots in a safe virtual environment, monitoring their sensors and developing code that determines their behaviour, before deploying them in the real world.
Because it needs no installation, OLO can be used from practically any device, and it runs on top of ROS 2, so each robot keeps its full features and capabilities.
The new partnership allows Scan to make its range of Unitree robots accessible to teams without specialist ROS developers, adding further value to the platforms.
Customers can pair a Unitree robot from Scan with OLO and go from unboxing to autonomous navigation, whether the goal is industrial inspection, academic research or prototyping.
Akash Raja, Director of Robotics at Scan, said:“OLO Robotics' innovative and user-friendly software perfectly complements our own ecosystem of GPU-accelerated robots, strengthening our position as a complete solution provider for robotics in the UK.”
Eleanor Tang-Smith, co-founder and COO of OLO Robotics, said:“Buying a capable robot has become straightforward. Getting it to do useful work is still the hard part, and it usually depends on specialist ROS engineers who are in short supply.
“Working with Scan means a customer can unbox a robot, connect it through a browser and start building inspection, research or prototyping applications without that barrier. Together we can give organisations a complete route from first idea to deployment.”
Scan is an Nvidia Elite Partner and OLO Robotics is a member of the Nvidia Inception programme. OLO Robotics will be at the Scan stand 3068 at Nvidia GTC Berlin, October 20-22nd.
Legal Disclaimer:
MENAFN provides the
information “as is” without warranty of any kind. We do not accept
any responsibility or liability for the accuracy, content, images,
videos, licenses, completeness, legality, or reliability of the information
contained in this article. If you have any complaints or copyright
issues related to this article, kindly contact the provider above.


Comments
No comment