

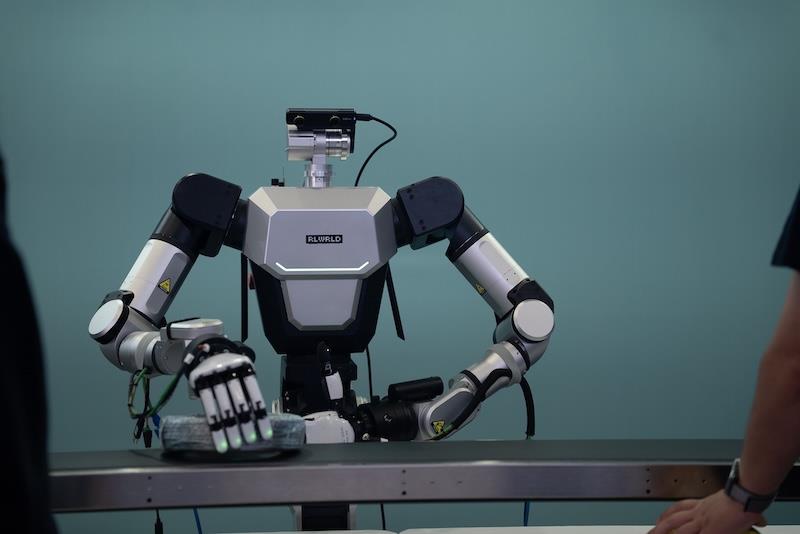
RLWRLD Outlines Physical AI Strategy For Industrial Humanoids


At the summit, the company shared its“Deployment-First” strategy, which starts with real-world industrial deployment, as well as its approach to advancing robotic dexterity for industrial applications.
Humanoids Summit is a global conference focused on humanoid robotics and physical AI. First launched in Silicon Valley in 2024, the event has since expanded to London, Tokyo and other cities, with Seoul hosting the summit for the first time this year.
The conference brought together humanoid and physical AI companies, researchers, investors and policymakers to discuss advances in the field and the path toward industrial deployment and commercialization.
Speakers at this year's summit included representatives from RLWRLD, FieldAI, Robotis, Lightwheel, Unitree Robotics, Nvidia, Qualcomm, Niantic Spatial, Bear Robotics, Amazon Web Services (AWS) and Renesas.
As an official Technology Collaborator and featured speaker, RLWRLD introduced itself as a“Deployment-First Frontier Lab” that puts real-world industrial deployment first.
The company outlined its physical AI strategy around robotic dexterity, a core capability required for humanoids and other robots to perform a wide range of tasks in industrial environments.
On the afternoon of September 22, Junghee Ryu, CEO of RLWRLD, delivered a keynote titled“Solving the Five-Finger Dexterity Problem: RLWRLD's Approach to Industry-Level Dexterity”.
Ryu presented deployment, industrial data and dexterity as three interconnected elements that form a reinforcing cycle at the core of RLWRLD's strategy. By deploying technology in industrial settings first, RLWRLD can accumulate data that is difficult to obtain in research environments.
Models trained on that data can then improve dexterous manipulation capabilities, enabling the technology to be deployed across a broader range of industrial settings.
Building on this cycle, Ryu emphasized RLWRLD's“Deployment-First” strategy, rather than completing research first and then bringing the technology into the field, RLWRLD starts in industrial environments and advances its technology through real-world deployment.
On the morning of September 23, Jeeyun Ahn, chief strategy officer (CSO) of RLWRLD, delivered a presentation titled“Scaling Dexterous Manipulation in the Real World”.
Ahn outlined RLWRLD's technology development approach, which uses data collected from industrial environments to continuously improve dexterous manipulation capabilities and extend them across different robot hardware platforms and task settings.
She emphasized that achieving the level of dexterity required in real-world industrial environments, and scaling those capabilities across a wider range of applications, is critical to bringing physical AI into practical industrial use.
RLWRLD is focused on advancing dexterity, the robotic manipulation capability that enables robots to precisely handle a wide range of objects and perform tasks in complex industrial environments.
In particular, the company is developing Robotics Foundation Model (RFM) technology that learns from data collected in industrial settings, improves robotic manipulation capabilities, and can be extended across different robot hardware platforms and task environments.
Alongside its technology development, RLWRLD is also advancing the real-world validation and commercialization of its physical AI technology. Most recently, the company expanded its collaboration with CJ Logistics in logistics-focused physical AI.
The two companies are jointly selecting logistics processes for initial application and conducting proof-of-concept (PoC) projects to validate key robotic tasks.
Both companies plan to move forward in stages with robotic hand and sensor integration, model training and fine-tuning using field data, and further technology refinement.
Based on validation in real logistics environments, RLWRLD and CJ Logistics also plan to jointly explore global business opportunities in logistics-focused physical AI.
Legal Disclaimer:
MENAFN provides the
information “as is” without warranty of any kind. We do not accept any
responsibility or liability for the accuracy, content, images, videos,
licenses, completeness, legality, or reliability of the information
contained in this article. If you have any complaints or copyright issues
related to this article, kindly contact the provider above.
Comments
No comment